PROJECTS
A collection of my work in robotics, autonomous systems, and software development. Each project represents a unique challenge in bringing intelligent machines to life, from reinforcement learning for bipedal locomotion to full-stack robotics platforms.
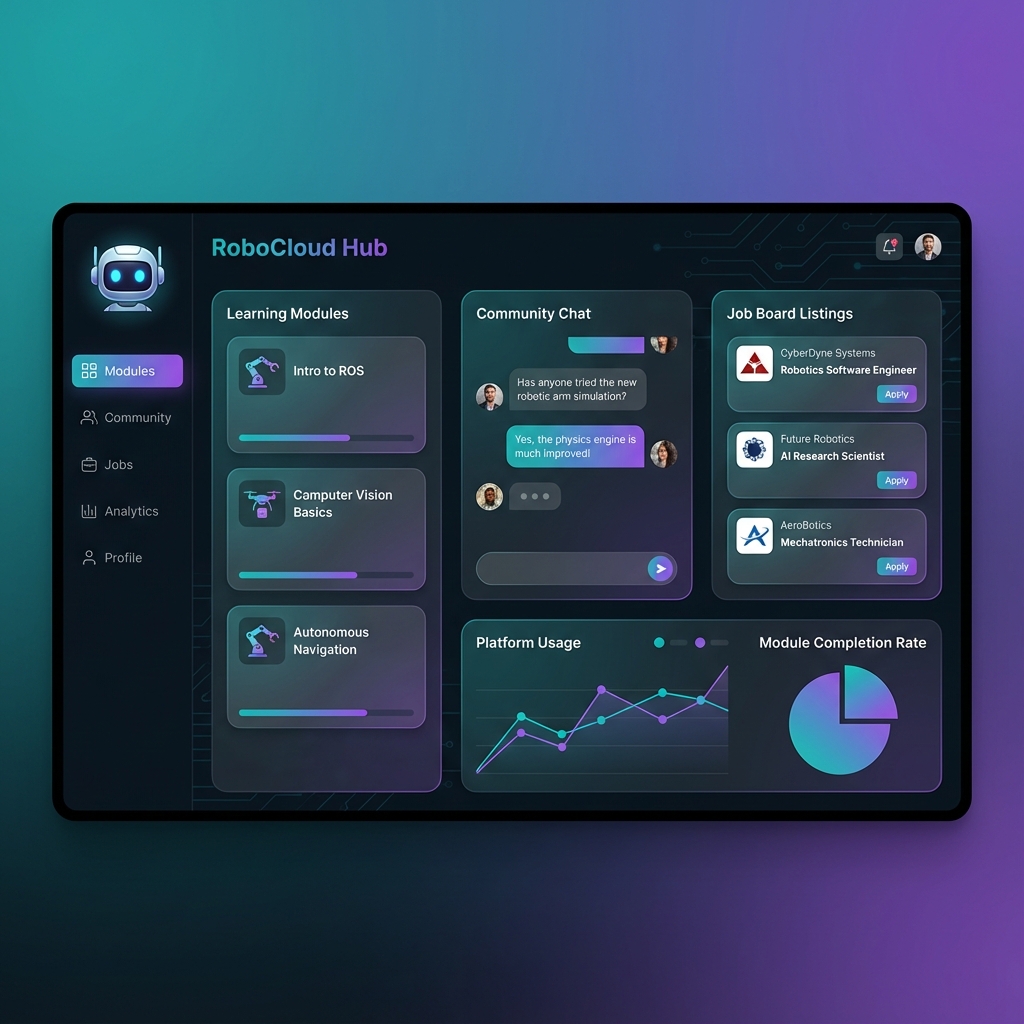
RoboCloud Hub
A unified platform for the robotics ecosystem: 475+ learning guides, DSA & interview prep, community forums, a job board, and a marketplace. Built with React, Node.js, and Prisma.
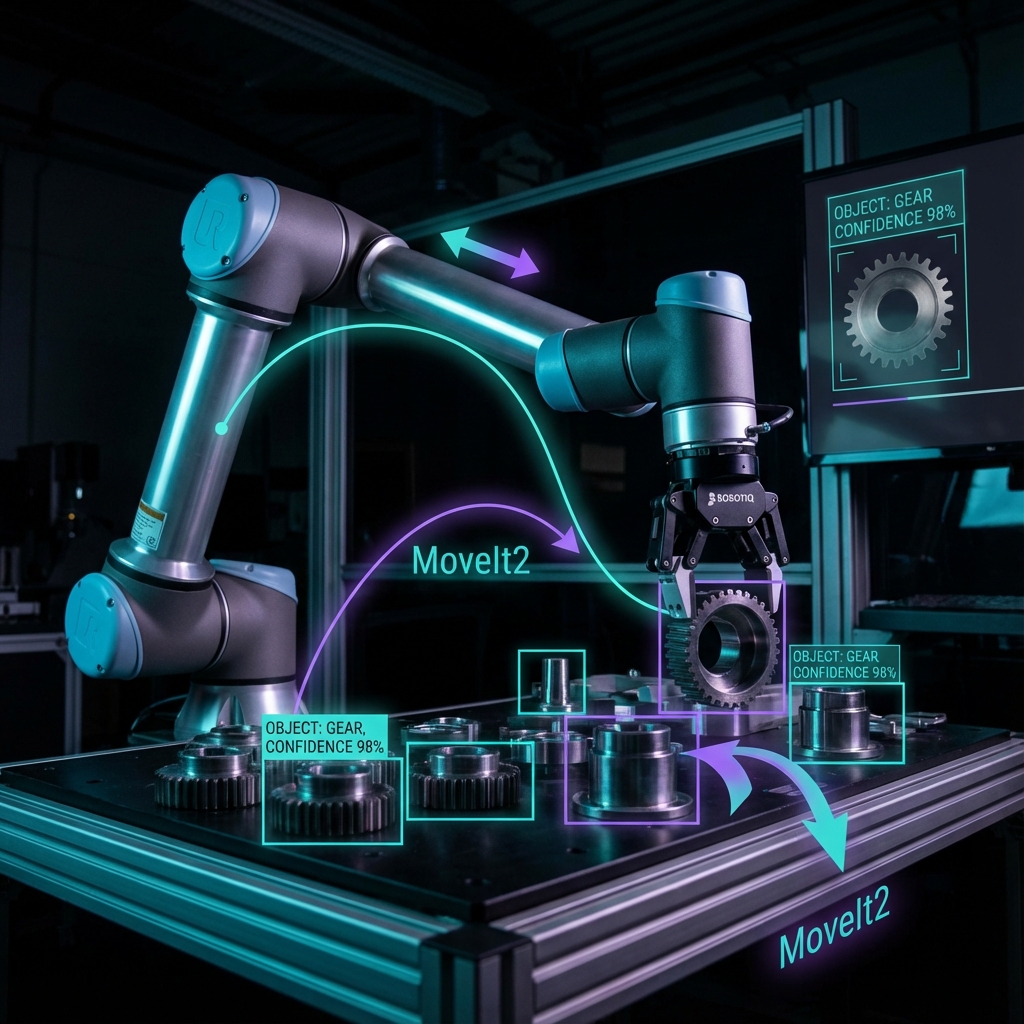
UR robotic arm with a Robotiq 2-finger gripper for ROS 2: MoveIt 2 motion planning, MTC task pipelines, PCL-based perception, and collision-aware grasping in Gazebo.
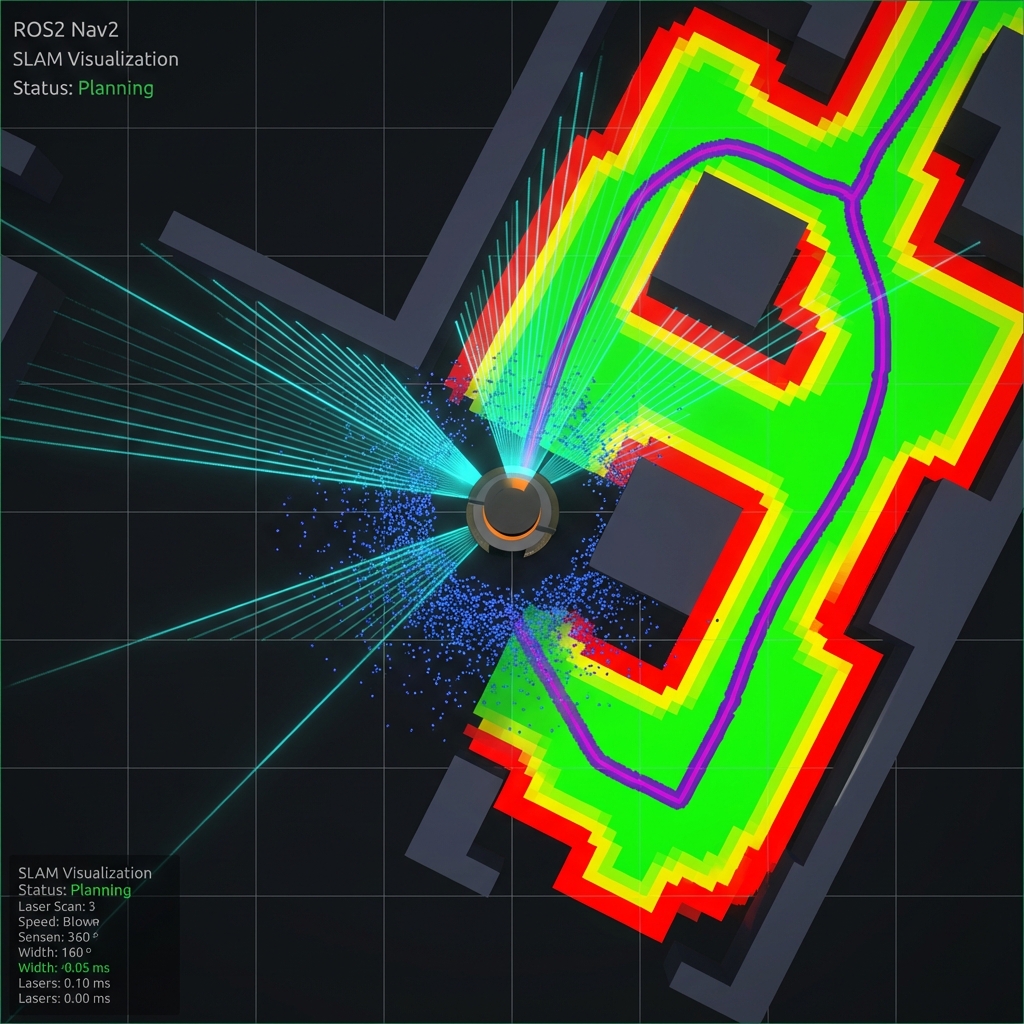
Full-stack ROS 2 autonomous navigation: Nav2, SLAM Toolbox, RTAB-Map 3D SLAM, and Gazebo Harmonic, with multi-robot fleet coordination, collaborative loop closure, coordinated frontier exploration, and an MPPI controller.
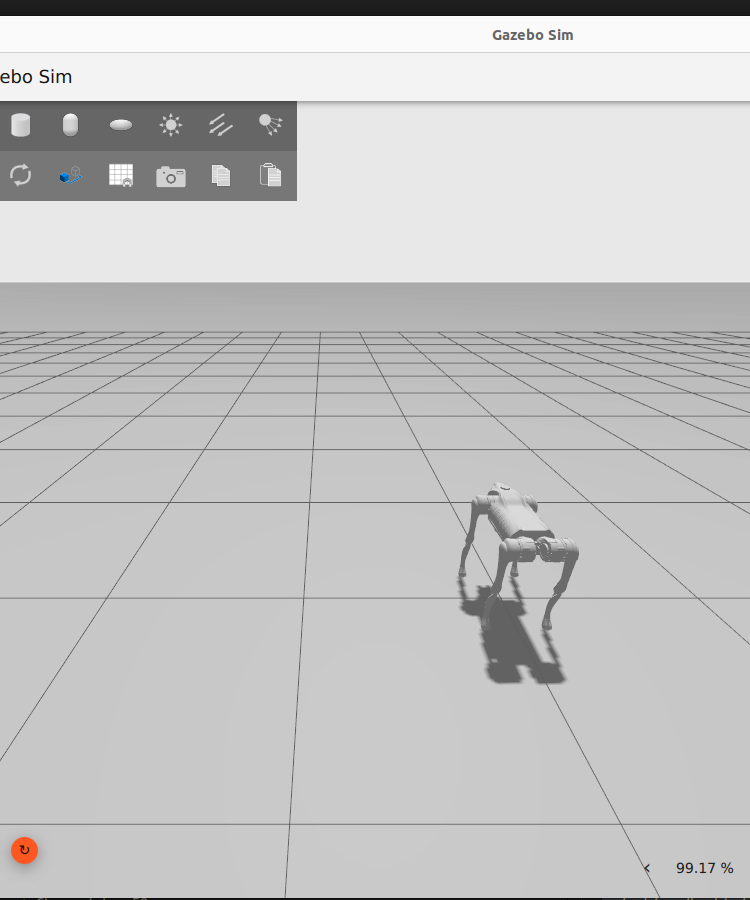
Unitree Go2 quadruped robot dog: RL locomotion training in MuJoCo and Gazebo Harmonic, ROS 2 CHAMP and Quad-SDK NMPC walking controllers, a PPO policy, keyboard teleop, and multi-terrain simulation.
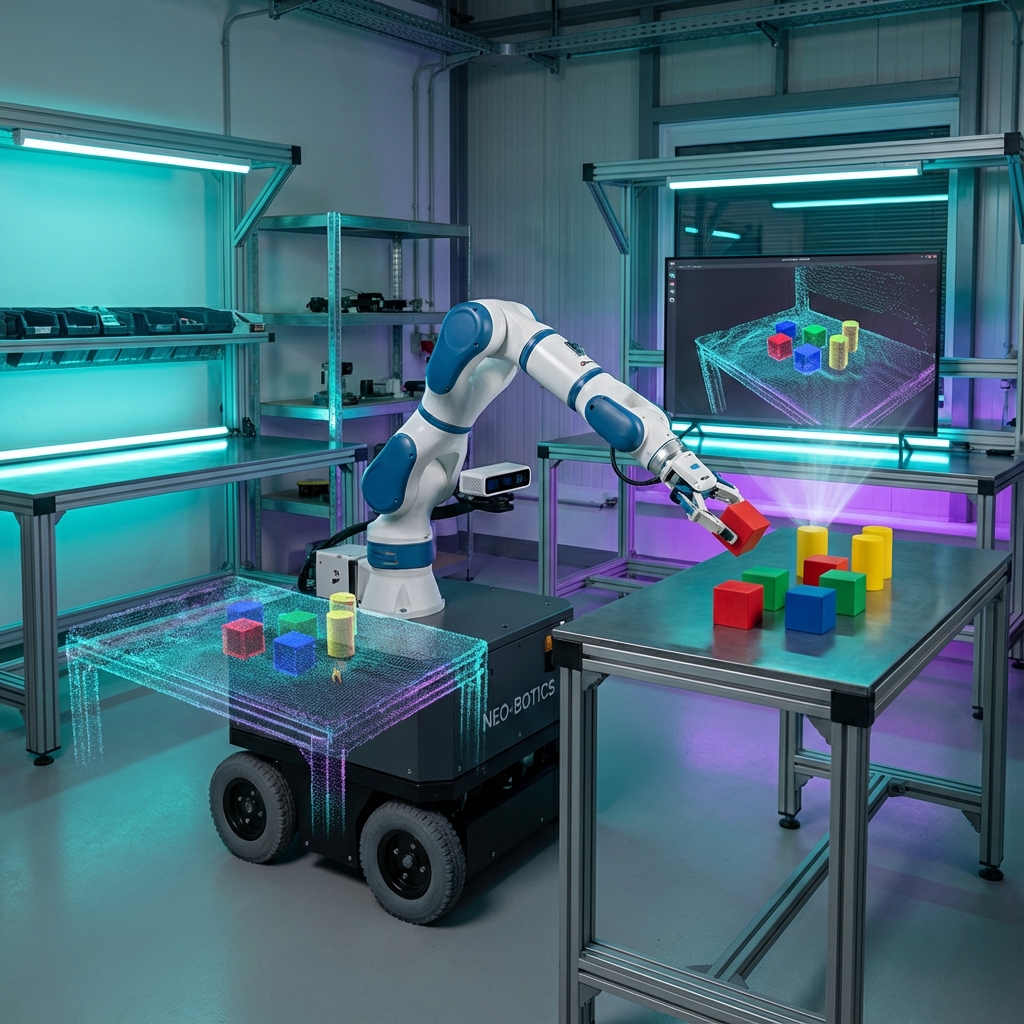
Mobile manipulator pick-and-place via reinforcement learning: a UR3 arm on a differential-drive base, trained end-to-end with TQC in Gazebo/ROS 2.
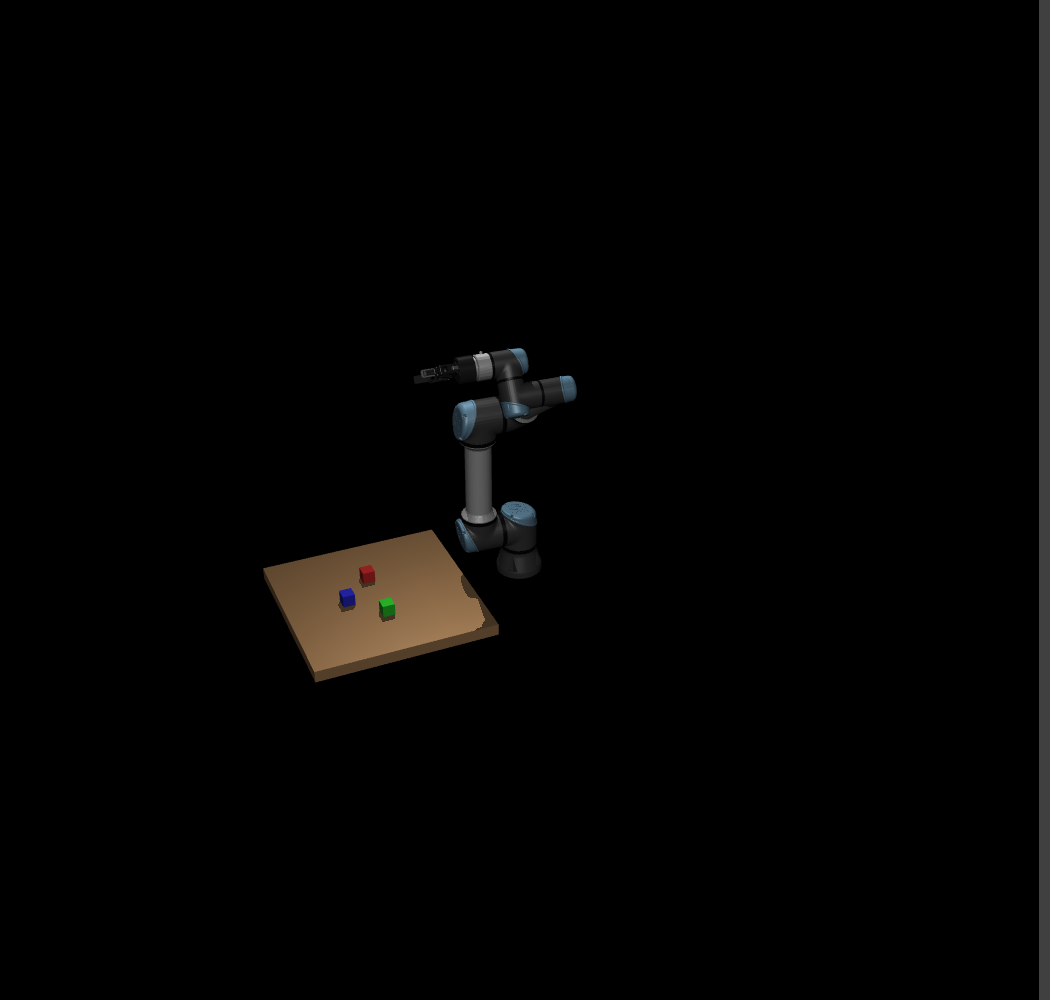
Reinforcement learning environment for UR5e arms with MuJoCo 3: SAC training for reach, pick-and-place, and symmetric multi-arm cooperative tasks, with a ROS 2 policy node for Gazebo deployment.
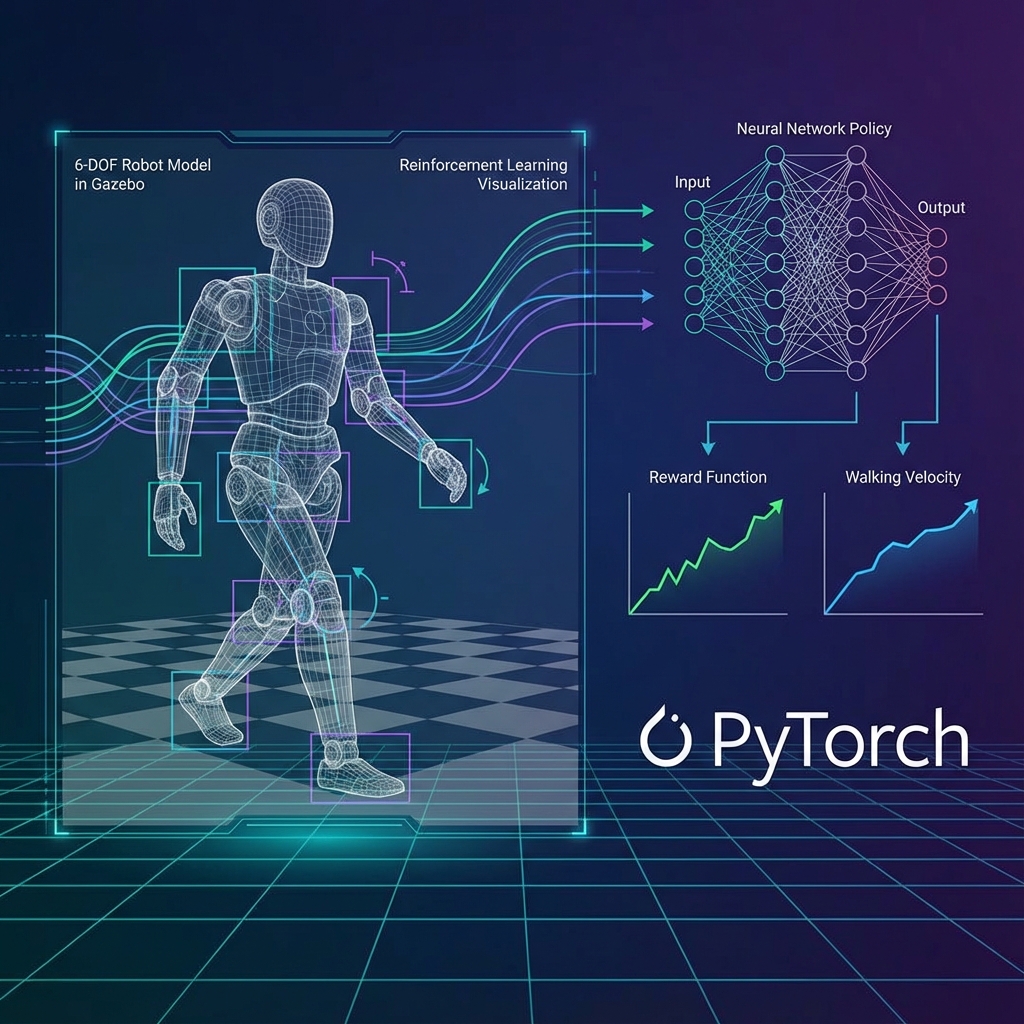
Reinforcement learning framework for bipedal humanoid locomotion, combining MuJoCo training with ROS 2 Humble deployment. Policies transfer sim-to-real via domain randomization and system identification.
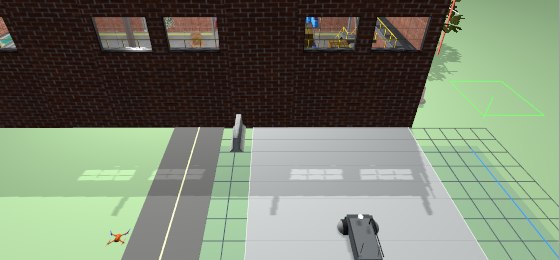
A simulated quadcopter UAV that flies an autonomous survey mission (RGB capture, depth-based coverage mapping, payload drop) and lands on a patrolling UGV it detects via an ArUco marker.